Advances in AI are rapidly improving robots’ ability to interpret instructions, reason through tasks, and plan actions. However, translating these decisions into reliable physical interaction depends on sensory information that many robotic systems still lack. Picking up an unknown object, maintaining a stable grip while it moves, or manipulating it without causing damage requires continuous information about the magnitude and direction of contact forces. Tactile feedback will therefore be essential if humanoid robots are to achieve a human level of dexterity.
Today, many robots still rely on simple grippers without tactile feedback or with contact force measurement limited to a single axis. At the other end of the spectrum, advanced multisensory hands remain largely confined to the research realm, where high costs, custom sensor architectures, and the complexity of integration hinder industrial implementation. So far, no clearly superior technology has emerged that can meet today’s requirements for sensing performance, ease of integration, and scalability, let alone keep pace with the evolving market for humanoid robotics.
Accelerating the Development of Physical AI
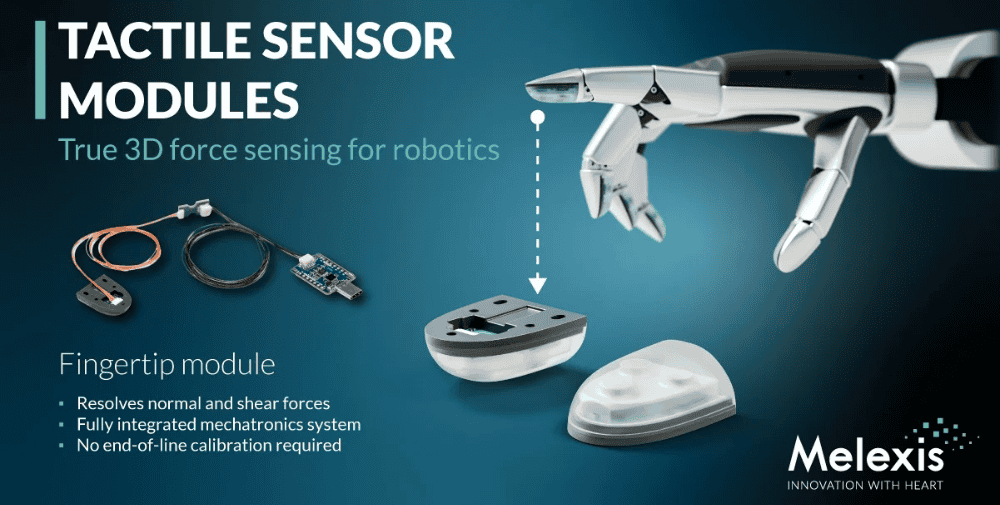
Melexis’s new fingertip module was developed to address this emerging market need by combining true 3D force measurement with the integration, readiness for deployment, and scalability required for the development of humanoid hands. Instead of merely measuring the force acting perpendicular to the sensor surface, it captures the contact force across three axes, measuring both the normal force and the shear forces in two directions. This determines both the magnitude and direction of the applied force, giving robots a far more comprehensive picture of grip stability, load movement, and the interaction between the fingertip and the object.
Based on Melexis’s magnetic Tactaxis® technology, it is the company’s first module to integrate a sensor, magnet, elastomer, mechanical structure, and supporting electronics into a single mechatronic fingertip module. Developing these interdependent elements as a complete system eliminates much of the complexity related to materials, assembly, and sensor technology that developers would otherwise have to resolve on their own.
Instead, the DVK90901 offers hand manufacturers a standard platform for faster benchmarking, prototyping, and system development, while robot OEMs can quickly begin generating the high-quality contact data required for the development and validation of control loops and physical AI. This creates a practical foundation that can be continuously refined as robotic capabilities and market requirements evolve.
From Sensor Technology to a Scalable Module
The MLX90901 measures normal forces in a range of 15 N and shear forces in a range of 4 N. It combines an accuracy of 10% of full scale with a typical resolution of 200 mN, enabling developers to detect even the smallest changes in contact force during realistic grasping and manipulation tasks. I²C support simplifies connection to robotic hand controllers and embedded development platforms.
The market launch marks the culmination of a four-year development phase for Tactaxis®. Melexis first demonstrated the underlying biomimetic sensor principle using individual “taxels,” allowing engineers to evaluate the technology as a concept. Customer testing and application development provided the insights needed at the system level to implement this sensor principle into a standardized fingertip module, combining research advances with Melexis’s expertise in product development and mass production.
A new evaluation kit also enables developers to test the MLX90901, characterize its three-axis force response, and begin integrating the module into robotic hand designs. This offers hand manufacturers and robot OEMs a straightforward way to evaluate Tactaxis® in light of new application requirements and to capture representative contact data.
Building a Tactile Platform for Humanoid Robotics
“When we began developing Tactaxis®, we observed how research in the field of tactile sensing was accelerating and recognized how closely this was linked to Melexis’s expertise in magnetic sensing,” said Julien Ghaye, Product Line Manager at Melexis. “With the MLX90901, we’ve gone beyond the sensor element and developed Melexis’s first complete mechatronic module. Taking responsibility for materials, mechanics, electronics, and integration demonstrates just how committed we are to humanoid robotics. We’re seeing this through to the end, combining scientific foresight with the experience needed for industrialization to deliver practical solutions today and work toward the scalability this market will require.”
The DVK90901 evaluation kit is available now. As the first standard Tactaxis® fingertip module, the MLX90901 forms the foundation upon which Melexis will build as humanoid robotics applications, performance requirements, and production volumes continue to evolve.
– – – – –
Related Links
👉 www.melexis.com
Photo: Melexis